An Optimization-Based Inverse Kinematics Solver for Safe Human-Robot Collaboration in XR Environments
Merle Meyer, Kristoffer Waldow, and Arnulph Fuhrmann
In: Virtuelle und Erweiterte Realität – 23. Workshop der GI-Fachgruppe VR/AR, 2026
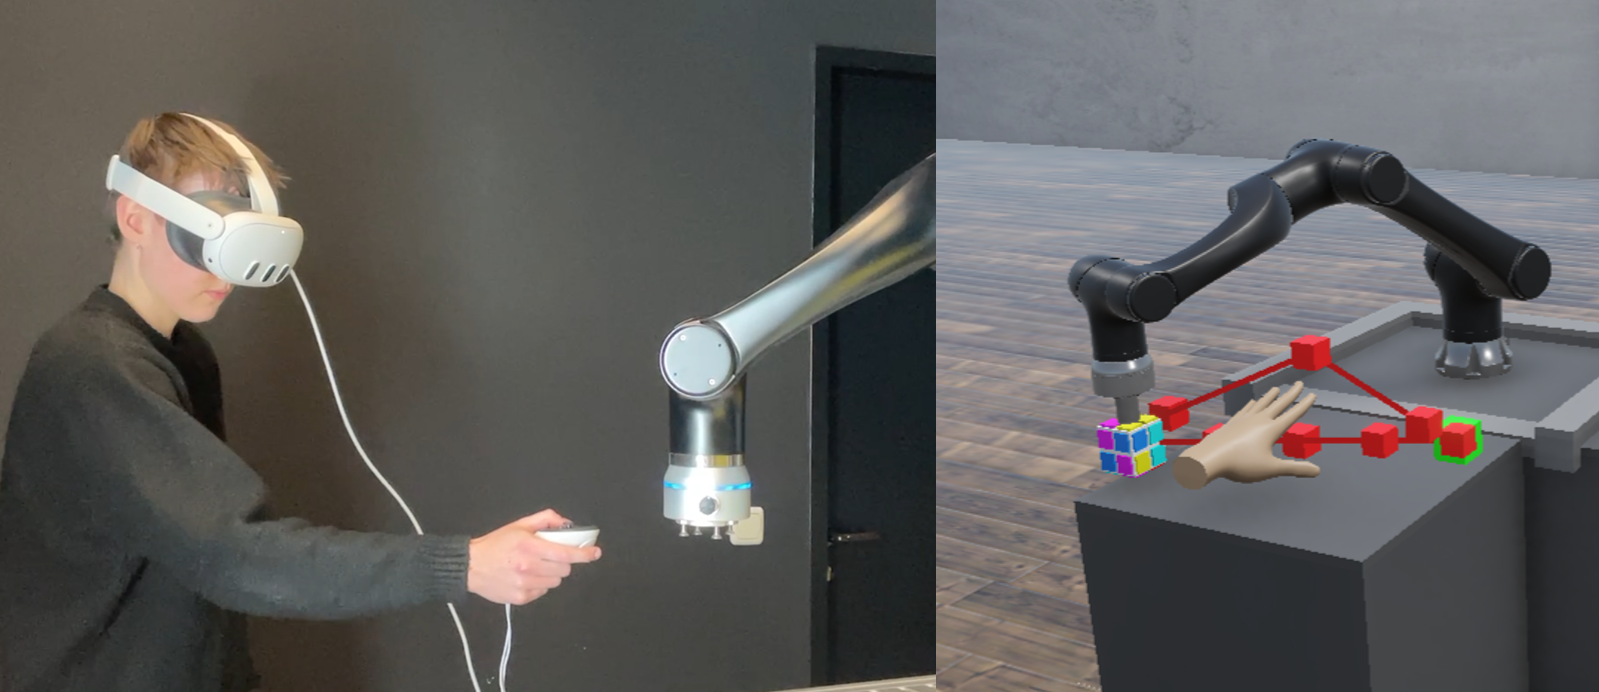
operated by a generic user. Prior to this a registration tool by Mertens et al. was used to align
the physical robot and its digital twin. If a collision is detected because the user’s hand crosses the direct path: the path points turn red and a collision-aware path is computed and visualized to the user
Abstract
Inverse kinematics (IK) plays a crucial role in Virtual/Mixed Reality (VR/MR) and Human–Robot Interaction (HRI), especially when users directly manipulate target positions for physical robots within immersive environments. Traditional analytical or heuristic IK solvers, such as FABRIK, offer efficient iterative solutions but often struggle with complex joint constraints, non-linear link geometries, and real-world mechanical limitations. In this work, we present a custom optimization-based IK solver for a multi-joint, 6 DoF robot integrated into VR/MR systems. We report preliminary findings on positional and rotational accuracy, compare our algorithm with established IK approaches, and outline future extensions for the collision avoidance and path prediction.